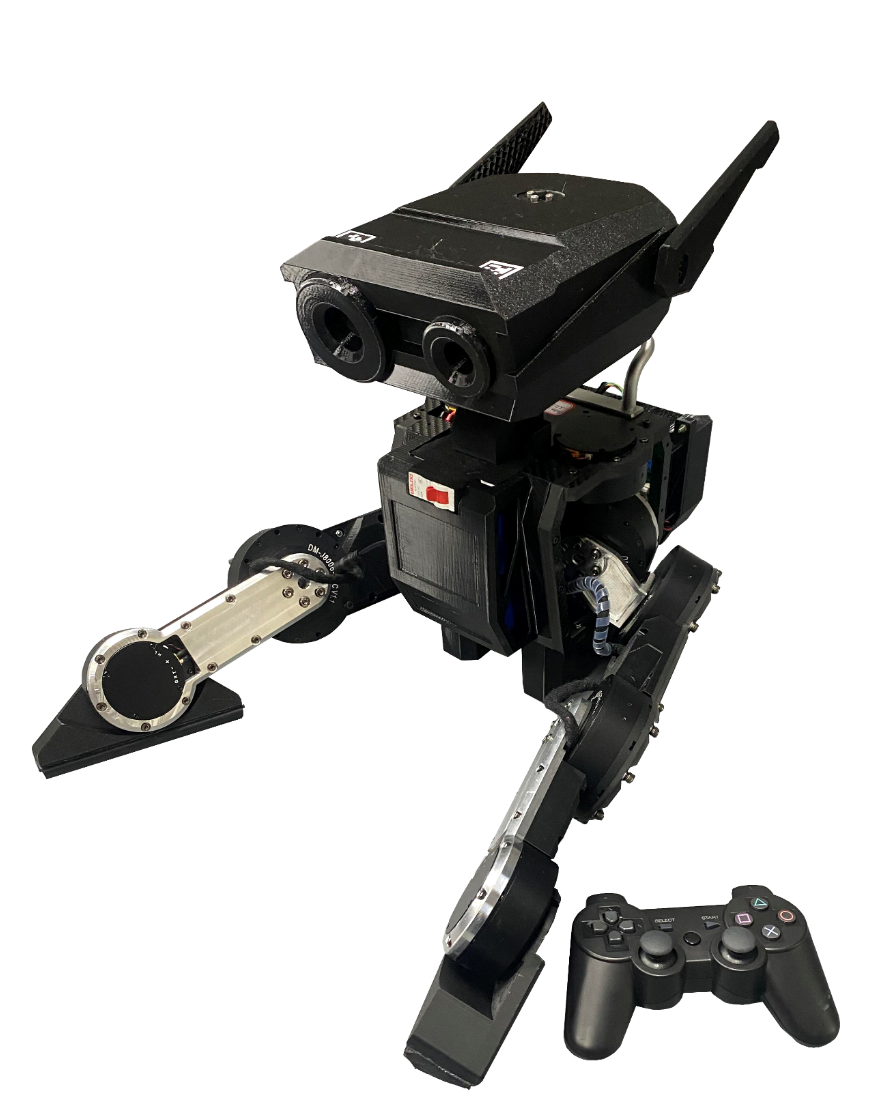
P1 is a compact legged robot built for research and education, offering dependable bipedal walking and an automatic safety-stop mechanism. Its multi-controller architecture and open software interfaces make it ready for reinforcement learning policy training and embodied AI algorithm validation.
Supports legged walking with a built-in gyroscope and accelerometer, and automatically stops safely when anomalies occur.
Provides secondary development interfaces and an RL training framework to accelerate algorithm research and deployment.
STM32 real-time control + Odroid C4 + Jetson Nano inference, with 4GB RAM and 64GB storage.
Peak torque of 20N·m at the knee and 12N·m at the ankle for more powerful motion.
| Height | 35 cm |
| Weight | 8 kg |
| Battery Life | 130 min |
| Main Controllers | STM32, Odroid C4, Jetson Nano |
| RAM | 4 GB |
| Storage | 64 GB |
| ARM Network Inference Processor | Arm Cortex-A55 |
| Charging Port | DC |
| Ethernet Ports | 3 × RJ45 |
| Sensors | Customizable on request |
| Degrees of Freedom (DoF) | 10 DoF |
| Yaw & Ankle Torque | Rated 4N·m, peak 12N·m |
| Roll, Pitch & Knee Torque | Rated 8N·m, peak 20N·m |
| Max Speed | 0.5 m/s |
| Legged Walking | Supported |
| Automatic Safety Stop | Supported |
| Inertial Sensors | Gyroscope + Accelerometer |
| API / Research Programs | Secondary development SDK + RL training framework |
* Specifications are subject to change without prior notice due to product improvements or updates.
Contact us for the product brochure, pricing, and partnership programs for universities and research institutions.